
Home / Case studies / AI Vehicle Damage Estimation for Commercial Truck Repair
Case study · Government & smart cities · Computer vision & edge AI
AI Vehicle Damage Estimation for Commercial Truck Repair
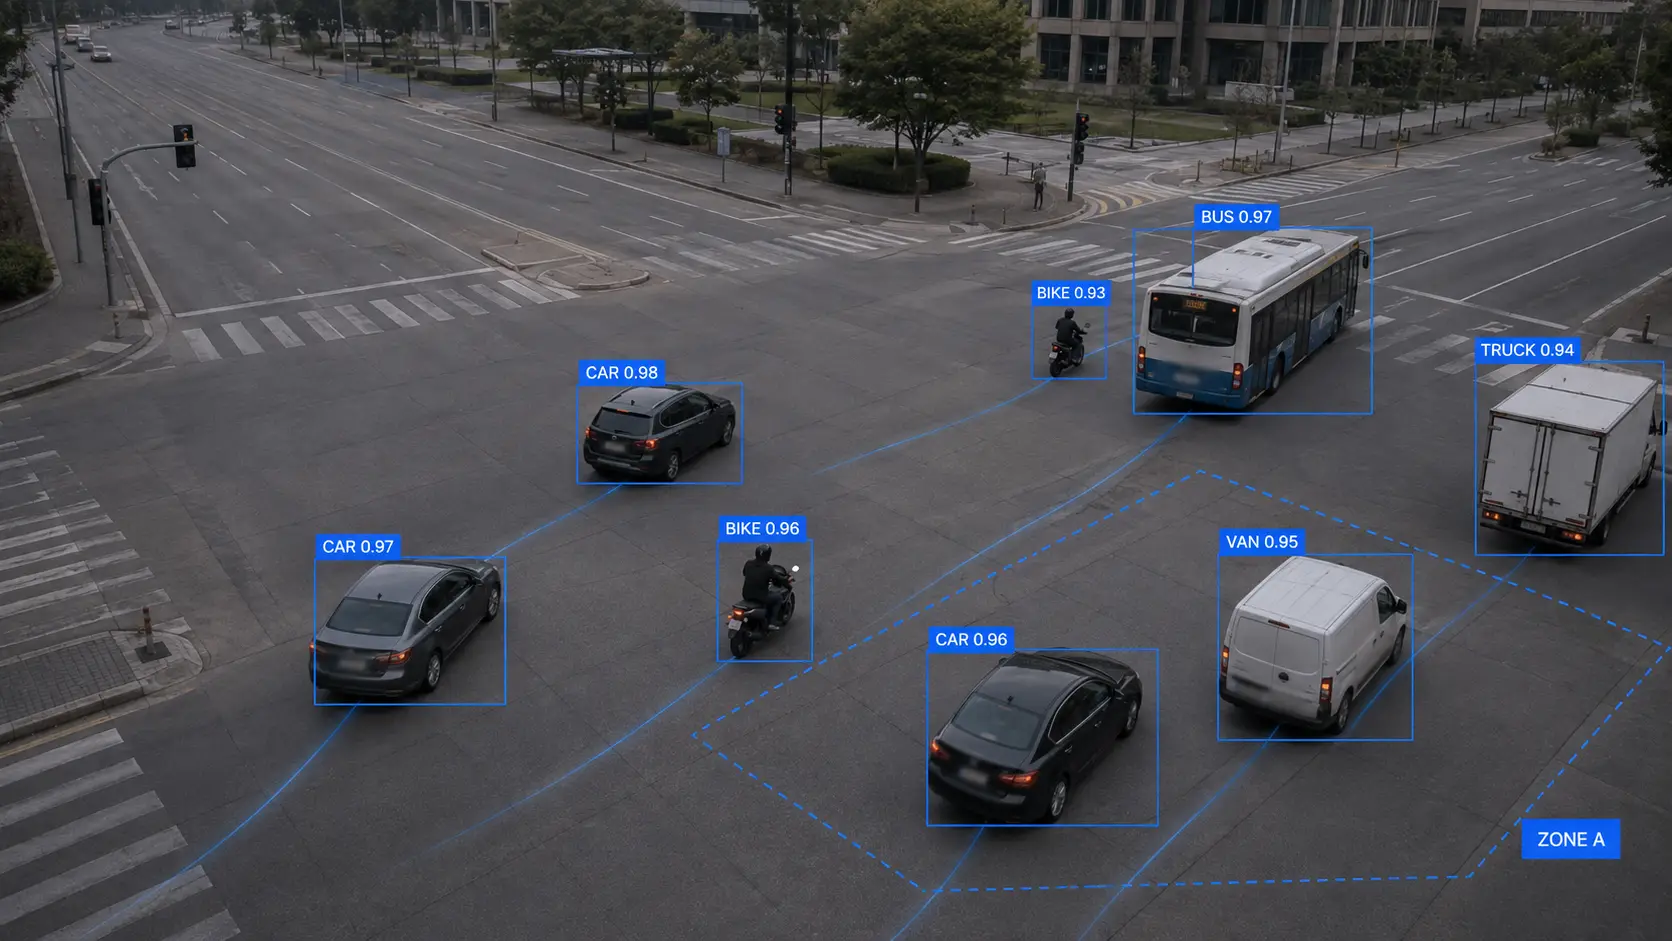
An Indian smart-city authority needed AI traffic violation detection, because manual patrols missed offences & hand-written challans kept causing disputes. Brainy Neurals built a roadside monitoring system that uses camera-based object detection to find vehicles, read number plates & flag broken rules. Units at each junction watch live video, & operators in one control room review the cases that officers once wrote by hand. Every challan now carries photo & video evidence & passes human review before it goes out.
10,000+
Images labelled for training
8
Violation types caught automatically
24/7
Counting by type, hour & junction
Published September 2026 · Updated October 2026
At a glance
What problem did this solve?
Manual traffic enforcement in a fast-growing Indian city missed violations & produced wrongly issued paper challans. Planners also lacked a reliable picture of how traffic moved through the city.
What did Brainy Neurals build?
Brainy Neurals built an AI traffic monitoring system for an Indian smart-city authority. Roadside units detect vehicles & flag eight violation types, then send each case with its plate read to a human review dashboard.
What changed after it went live?
Cameras now catch violations with photo & video evidence, & every challan passes human review. Traffic counts by vehicle type now guide the city’s road & enforcement planning.
Who else could use this?
Roadside AI monitoring fits operators of roads, parking, yards & large sites. It suits any place where cameras must catch an event the moment it happens.
| Detail | This engagement |
|---|---|
| Industry | Government & smart cities |
| Sub-vertical | Urban traffic management |
| Client | Indian smart-city authority |
| Engagement | AI traffic monitoring platform |
| Timeline | Not disclosed |
| Capabilities | Computer vision, edge AI, ANPR |
| Delivery model | Project-based delivery |
Why did manual enforcement keep failing?
Manual enforcement kept failing because it depended on whichever officer happened to watch a stretch of road at that hour. An Indian smart-city authority needed AI traffic violation detection for junctions where cars, buses, trucks, auto-rickshaws & two-wheelers share one road. The city had cameras but no video analytics behind them, so planning ran on complaint letters & occasional counts.
- An officer could watch one corner of a busy junction while the violation happened at the other three.
- Challans were written out by hand, & a misread plate sent the fine to the wrong owner.
- Each dispute came down to word against word, because neither side held any evidence.
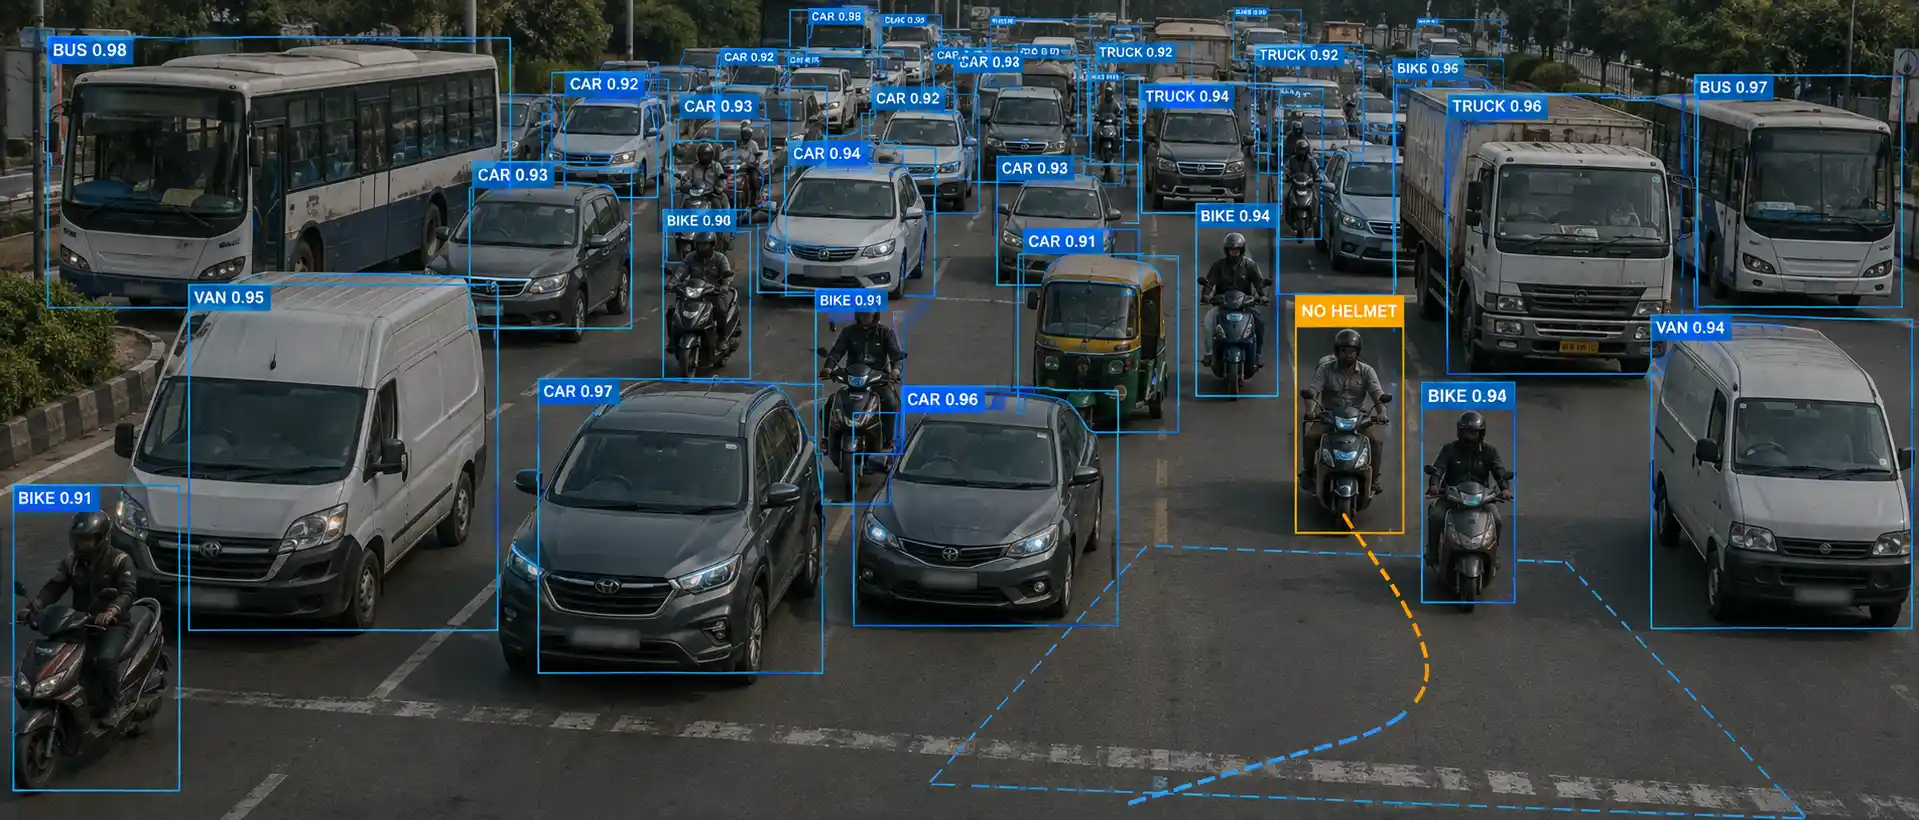
- Riders without helmets passed through freely whenever the nearest enforcement post stood empty.
- Planners choosing sites for a flyover or a one-way corridor had opinions in place of counts.
The stakes were real, because helmets cut a rider’s risk of death by roughly two fifths[1]. Every junction left unwatched carried that cost for riders.
What do cities usually try first?
Cities usually try one of four routes first, & each of them stops somewhere specific. The fourth route is the one we shipped.
| Route | What it gets right | Where it stops | Who it still suits |
|---|---|---|---|
| Manual patrols | Human judgment on the spot | One pair of eyes per post | Rare, complex situations |
| Cloud video analytics | Any model size, central updates | Bandwidth & latency per junction | A few cameras on strong links |
| Standalone smart cameras | Quick to install | Fixed functions, closed firmware, siloed data | Single-purpose pilots |
| Edge AI units (our route) | Real-time detection, one city data pool | Weeks of engineering per board | Cities running cameras in volume |
A 2016 survey of edge computing named response time & bandwidth cost as reasons to process data at its source[2].
Three common routes each stop at a wall that the edge route never meets.
How we designed AI traffic violation detection
Brainy Neurals built a fleet of roadside units feeding one control room for an Indian smart-city authority. Each unit runs real-time object detection & multi-object tracking on every stream it captures, then reads the number plates. Only events & their evidence bundles travel upstream, along with the traffic counts.
Where the detection runs
The first decision was where the intelligence in this system would live. Streaming every junction’s video to a data center would cost more in bandwidth than the hardware it replaced. So detection runs at the roadside, on a low-cost embedded board with an AI accelerator.
Who issues a challan
The second decision was who gets to issue a challan. The detector flags a violation & assembles its evidence, then a person approves or rejects the case. A wrong challan costs a city more trust than a missed violation ever will.
A wrong challan costs a city more trust than a missed violation ever will.
Operators shape the system themselves by drawing restricted zones straight onto each camera’s view. They attach a new stream by pasting its address & detach one just as fast. When an uplink drops, the unit keeps working & syncs its cases once the network returns.
Detection & plate reading run at the roadside, & only events with their evidence leave the unit.
The technology stack we used
Every layer of the stack had to survive a roadside cabinet on a public budget, which is the whole discipline of edge AI. The build ran as a pipeline of eight stages: collect, annotate, train, validate, optimize, field test, deploy & operate.
More than 10,000 annotated images moved through this pipeline before the first junction went live.
The roadside unit
| Layer | What we used | Why | What we ruled out |
|---|---|---|---|
| Cameras & streams | IP cameras or recorded video | Reuse what junctions already have | Proprietary camera lock-in |
| Compute | A low-cost embedded AI board | Affordable citywide | Industrial PCs |
| Runtime | The board’s accelerated video pipeline | No frame copies, hardware decode | Generic CPU processing |
The models
| Layer | What we used | Why | What we ruled out |
|---|---|---|---|
| Detector | A single-stage vehicle detector | One pass per live frame | Two-stage detectors |
| Tracker | A lightweight multi-object tracker | One vehicle stays one vehicle | Fresh detection every frame |
| Plate reader | ANPR tuned on regional plates | Challans need a plate | Cloud OCR services |
Control room & cloud
| Layer | What we used | Why | What we ruled out |
|---|---|---|---|
| Control room app | A native C++ desktop application | Live walls, playback & plate search | A browser-based video wall |
| Data store | Sealed evidence & audit logs | One citywide, audit-ready picture | Data siloed per junction |
| Data chat | A language model over the data | Plain-language questions behind authorized access | Fixed report menus |
How does one violation get caught?
One violation gets caught in six steps, in the order the roadside unit sees them.
Every flag waits for a human decision, & only an approved case becomes a challan.
- A junction camera streams live video to the roadside unit, alongside the other streams it already carries.
- The detector finds every vehicle in the frame & labels it as a car, bus, truck, auto-rickshaw or two-wheeler.
- The tracker follows each vehicle across frames, so one vehicle stays one vehicle from entry to exit.
- A track that breaks a drawn rule raises a flag, as does a wrong-way run or a rider without a helmet.
- The unit reads the number plate & checks it against the watchlist. It then saves stills & a clip as evidence.
- The case lands in an operator’s review queue, & only an approved case ever becomes a challan.
A person always holds the last of those six steps. A watchlist hit also fires an instant alert, because a stolen vehicle can’t wait for a review queue.
What problems nearly stopped the build?
Four problems nearly stopped the build, & they arrived in the order below.
Models broke on real junctions
The first detection models broke on real Indian junctions. Five vehicle classes appeared at every distance, overlapping & weaving, from angles no public dataset covers.
Plates fought back
Number plates fought back next, with dirt & bent metal on many of them. Non-standard fonts & two-wheeler plates half the size of a car’s made reading harder.
The board sank
Then the board sank under the load. A single unit had to carry several live streams, & every naive pipeline copied frames until the frame rate died.
Wrong challans went out
The very first automated challans included wrong ones. A wrong challan is worse than a missed violation, because the mistake now has a victim.
At four in the morning, the test junction belonged to street dogs & newspaper vans.
An embedded benchmark measured co-processor detection running roughly ten times faster than the same models on a CPU[3]. These are the weeks when a city’s integrator brings in specialist engineers.
How we fixed each problem
We fixed each problem in turn, starting with detection on real junctions.
Detection
We collected footage across several Indian cities & annotated more than 10,000 images across five vehicle classes. The detector was retrained until live junctions stopped surprising it.
Plates
ANPR number plate recognition needed its own discipline, starting with a reader tuned on regional plates. We also let the tracker vote across frames, because one clean read beats twenty blurry ones.
Streams
We moved the whole pipeline onto the board’s accelerated path, so frames are decoded & batched for inference without copies. The unit now carries its full set of live streams, & a watchdog restarts any that die.
Wrong challans
We put a person in the loop, so the system flags each case with its evidence & then waits. An operator approves or rejects every case, & nothing reaches a vehicle owner unreviewed. Duplicate flags collapse into one case, & every decision is logged.
Surfacing problems like these early is exactly what an AI proof of concept is for.
What changed after go-live?
After go-live, violations get caught on camera & every challan carries evidence a person has reviewed.
| What | Before | After |
|---|---|---|
| Catching a violation | An officer had to see it | A camera sees it, with evidence |
| Issuing a challan | Written by hand at the roadside | Reviewed on a dashboard, evidence attached |
| Settling a dispute | Word against word | Photo & video on record |
| Counting traffic | Occasional manual surveys | Continuous, by type, hour & junction |
| Finding one vehicle | Hours of scrubbing footage | A plate or description query |
The number we do not have
We haven’t published violation-volume or dispute-rate figures, though the client reports that errors, effort & disputes all fell. A number we haven’t measured is a number we won’t print.
The counts now decide real things, such as where a new bridge should split the load. They also decided which corridors should turn one-way & where officers should stand at each hour.
Plate reads map journeys & corridor times across the whole network. The same vehicle mix now feeds the authority’s area-by-area pollution estimates.
See what your junctions could catch
Tell us which cameras you run & which violations slip through today. We can scope a pilot at one or two junctions, or you can check your AI readiness first.
What is running today
AI traffic monitoring now runs in production across the authority’s junctions. Operators attach a stream by pasting its address & then draw its violation zones. They search recorded footage by plate, vehicle type or colour.
A watchlisted plate raises an alert the moment any camera reads it, which leaves a trail for stolen-vehicle cases. A dead stream restarts itself, & model updates roll out junction by junction.
Since handover, the authority also questions its data in plain language, behind authorized access. It follows the same shape as our transportation work, deciding at the camera & reporting upstream.

What would we do differently?
We would change four things if we built this system again.
Put human review in on day one
We added review after the first wrong challans went out, then spent weeks earning that trust back. Human review should have shipped on day one, not after the first wrong challan.
Human review should have shipped on day one, not after the first wrong challan.
One city’s footage is not a dataset
Our first training set came from too few angles, & the junctions punished it. Collect footage widely before you train anything at all.
Give operators the zone pen early
Every junction enforces its own local rules in its own way. Hard-coded zones meant a site visit for every change, & drawable zones ended that.
Give plates their own timeline
Vehicle detection & plate reading feel like one problem, yet they are two. Plates took their own tuning passes, & planning them apart would have saved us weeks.
Where else does roadside detection fit?
The pattern behind AI traffic violation detection fits anywhere an event must be caught the moment it happens. Roadside AI monitoring finds vehicles & people in live video by running detection on hardware at the site itself.
| Industry | The equivalent problem | What changes in the build |
|---|---|---|
| Parking operators | Occupancy & overstay, counted continuously | Retrain on bays & add duration rules |
| Construction | Hard hats & site safety at the gates | Helmet detection ports almost unchanged |
| Manufacturing | Forklift lanes & PPE at machine cells | Tighter timing, with a signal to the line |
| Logistics yards | Gate check-in & dock counts on patchy networks | More pixels for plates on trucks |
| Campuses & venues | Entry counting & incident flags across many cameras | Fewer vehicle classes, more people logic |
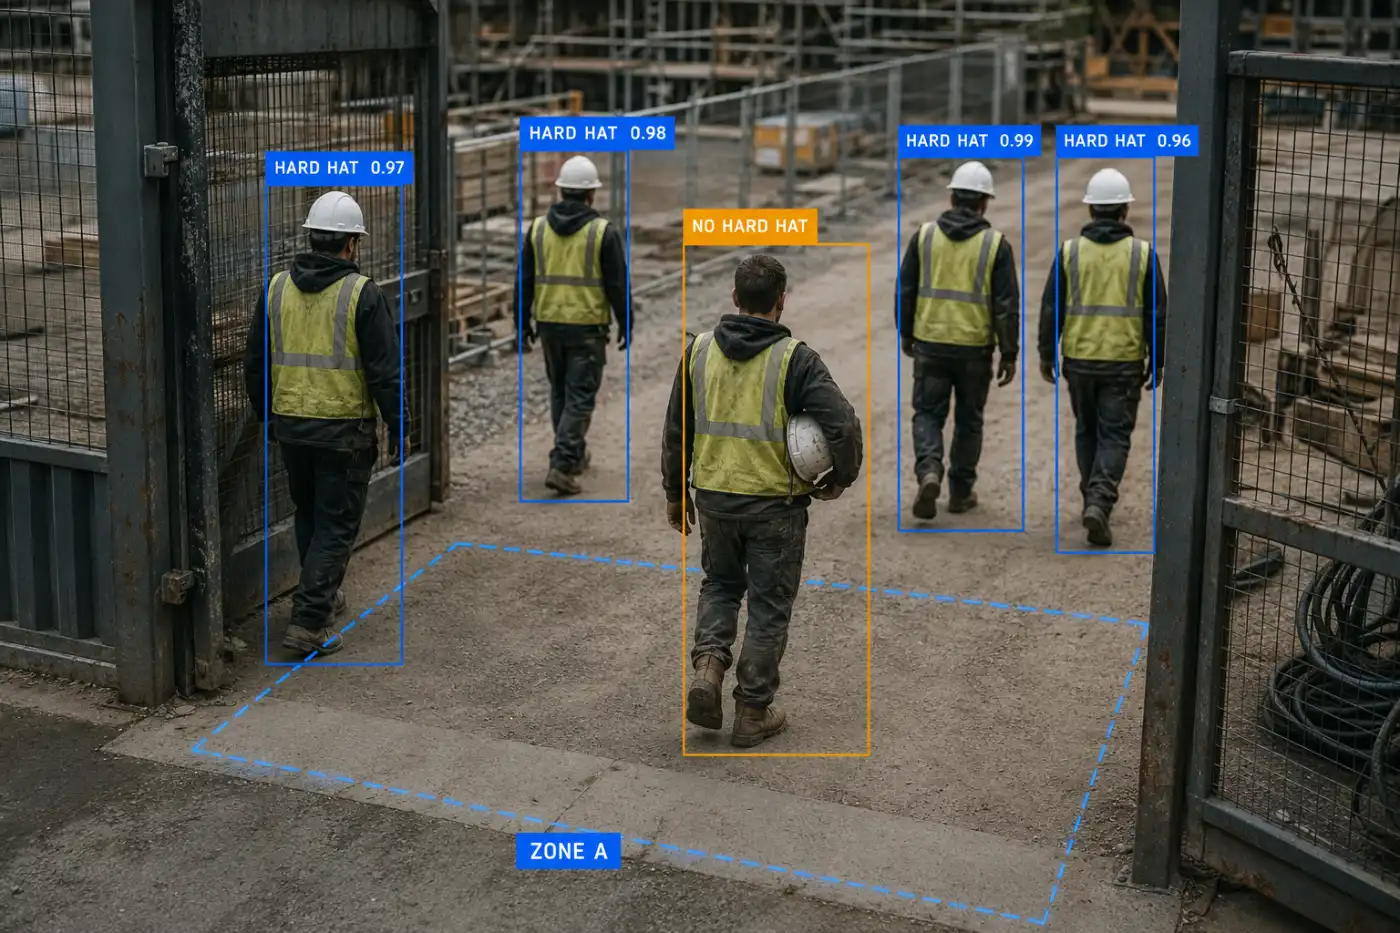
Porting it takes a retrained detector & redrawn zones, plus a synced watchlist & a proper field test at the new site.
Questions buyers usually ask
How it works
How does AI traffic violation detection work on a camera?
A detector finds each vehicle in the frame, & a tracker follows it across frames. When a track breaks a rule drawn for that camera, such as a banned U-turn, the system flags it & captures the stills & clip in that moment.
Which violations can be caught automatically?
This build flags eight violation types, each with a plate read & evidence behind it. They cover banned U-turns, wrong-way driving, signal jumps, missing helmets, triple riding, missing seatbelts, no-parking stops & restricted corridors. New types need new zones or training data, not new hardware.
Does the video leave the roadside?
Live streams are processed at the junction unit itself. Only cases, evidence clips, plate reads & counts move to the cloud store, behind authorized access. Continuous video never streams to a data center.
Time, cost & rollout
What happens when the AI gets it wrong?
Nothing reaches the public, because the design stops it. A flagged case waits in a review queue where an operator checks the evidence & approves or rejects it. A rejected case is closed, & no challan ever comes from it.
How long does a city pilot take?
A working pilot at one or two junctions usually takes a few weeks once cameras & access exist. Detection quality & plate reading each need a tuning pass, & so does the review workflow. A citywide rollout follows the pilot’s evidence.
How much does AI traffic monitoring cost?
Cost depends on the number of junctions & on the camera estate already in place. Brainy Neurals scopes it from a short conversation & a look at the sites, then quotes a fixed price. An AI readiness assessment tells you first whether your cameras & network can carry it.
What should your cameras be catching?
Describe your junctions, your cameras & the violations that slip through today. One reply comes from the engineer who would design the system, with a plain view of what a pilot needs.
Services behind this case study
These Brainy Neurals services went into the build, from the roadside camera to the control room.
Video analytics
Multi-camera monitoring that turns raw junction footage into events, evidence, alerts & searchable history.
Computer vision development
Detectors & trackers trained on your objects & tuned for the streets they watch.
Edge AI & embedded services
Real-time inference on low-cost roadside hardware, sized for every stream it has to carry.
Generative AI development
Language interfaces over live operational data, so planners can ask questions in place of pulling fixed reports.
Hire AI developers
Vision & edge engineers who join your team for the weeks when the streets fight back.
AI in logistics
Gate & fleet monitoring for yards, built for operators who move vehicles all day long.
A single-junction AI proof of concept is the fastest way to test all of this. AI consulting helps choose the hardware first, & an AI readiness assessment checks whether your cameras can carry it. The industries hub shows where this pattern already runs.
Similar case studies
Three more Brainy Neurals builds each shipped into a real environment in place of a demo.
Overhead Line Geometry Measurement
Stereo cameras on a moving train measure live wire geometry, with inference running on the train itself.
AI Diet Assistant for Gastroenterology
Clinical dietary guidance is generated under review gates, live in a real healthcare setting.
Personalised AI Meal Planning for Chronic Care
Structured meal plans are built from messy personal health data, grounded & sourced so a person can review them.
Cite this case study
Patel, Mitesh. AI Traffic Violation Detection for Smart Cities. Brainy Neurals, August 2026. https://brainyneurals.com/case-studies/ai-traffic-violation-detection/
Sources cited on this page
- Liu BC, Ivers R, Norton R, Boufous S, Blows S, Lo SK. Helmets for preventing injury in motorcycle riders. Cochrane Database of Systematic Reviews. 2008;(1):CD004333. DOI 10.1002/14651858.CD004333.pub3.
- Shi W, Cao J, Zhang Q, Li Y, Xu L. Edge Computing: Vision and Challenges. IEEE Internet of Things Journal. 2016;3(5):637-646. DOI 10.1109/JIOT.2016.2579198.
- Cantero D, Esnaola-Gonzalez I, Miguel-Alonso J, Jauregi E. Benchmarking Object Detection Deep Learning Models in Embedded Devices. Sensors. 2022;22(11):4205. DOI 10.3390/s22114205. PMID 35684827.